GRFKalmanAGJW
Download script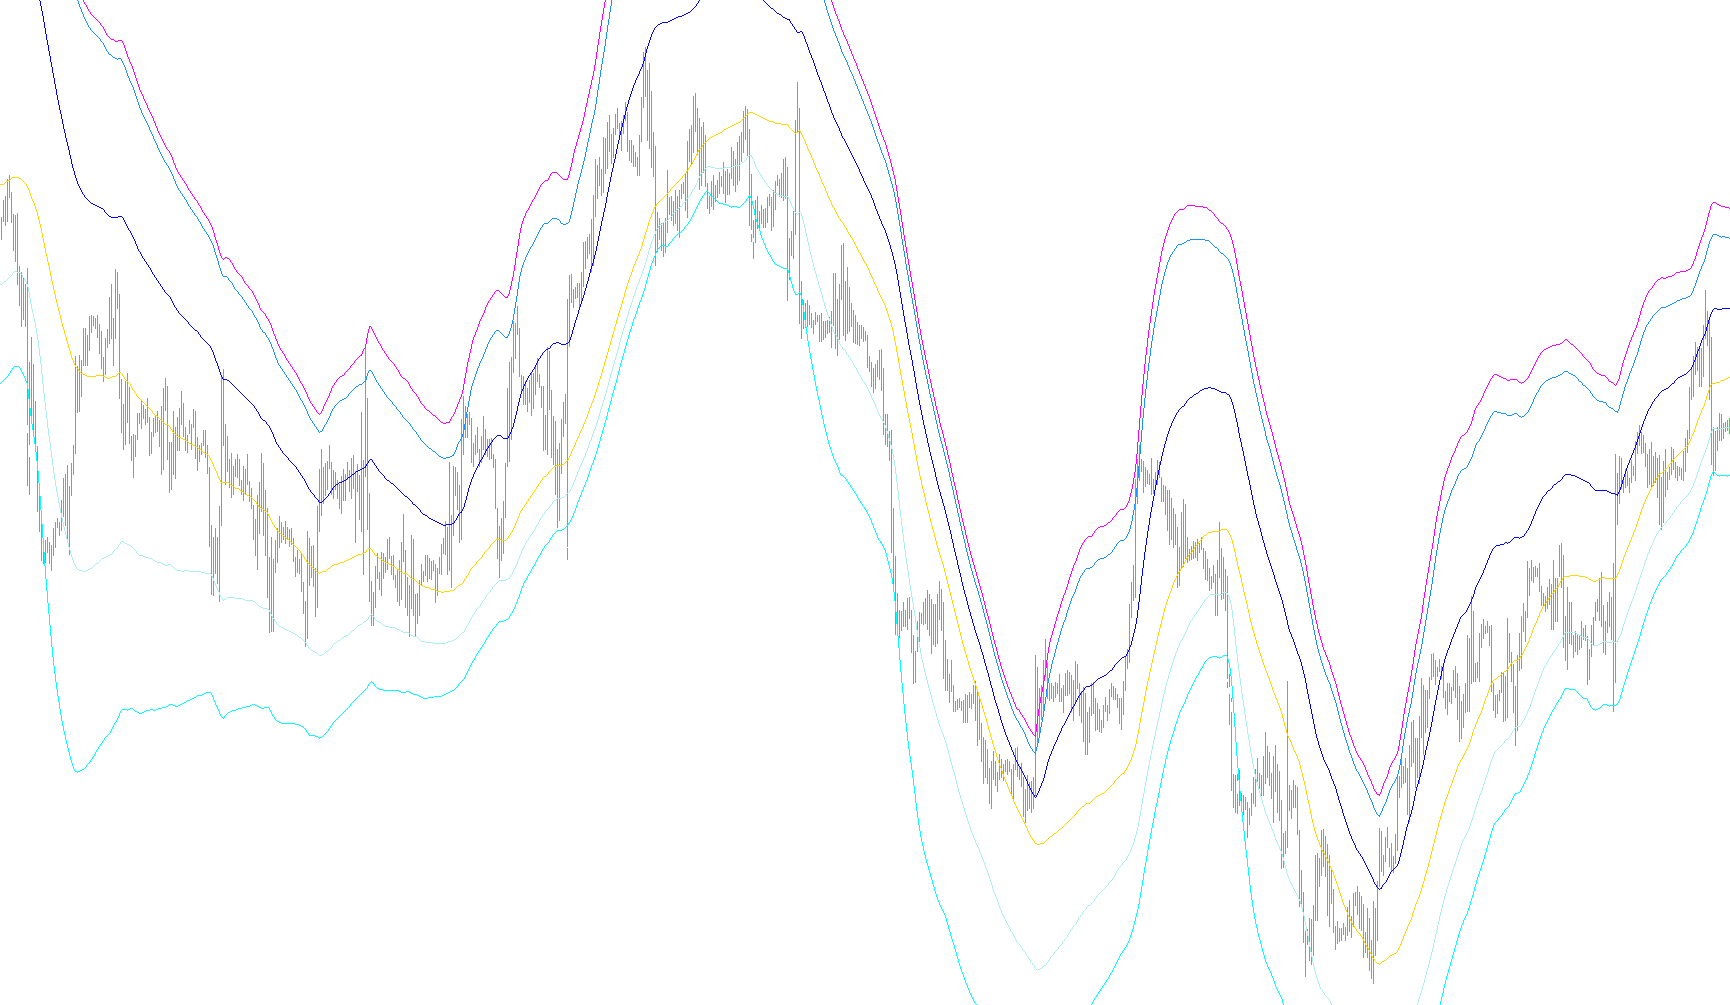
This script is a sophisticated technical analysis tool designed for the MetaTrader platform. It utilizes a mathematical framework known as a Kalman Filter to track and project market trends. Instead of using simple moving averages, which often lag behind price action, this tool attempts to "smooth out" market noise to identify the true underlying direction of the price.
Here is a breakdown of how the logic operates in plain language:
Core Mechanism: The Kalman Filter
The primary engine of this script is the Kalman Filter. Think of this as an intelligent tracking system (similar to those used by GPS or radar). It takes a series of messy, fluctuating market data points and calculates the most likely "true path" of the price. It does this by constantly balancing two factors:
- The Prediction: Based on where the price was and how fast it was moving, where is it likely to be next?
- The Measurement: What is the actual price currently showing?
By weighing these two against each other, the script creates a smooth trend line that reacts more intelligently to sudden price spikes while remaining steady during minor fluctuations.
Trend Tracking and Volatility
The script doesn't just look at the current price; it looks at the "energy" of the market:
- Dynamic Deviations: It calculates "Standard Deviations" (volatility bands). These act like boundaries. When the price stays within these bands, the trend is considered stable. When it pushes toward the edges, the script identifies potential shifts in momentum.
- Auto-Gain Logic: The tool features an intelligent "Auto-Gain" system. This means it can automatically adjust its sensitivity based on market conditions. If the market becomes extremely volatile, the tool can dampen its reactions; if the market is calm, it can become more responsive to subtle movements.
Predictive Capabilities
One of the most advanced features of this script is its ability to "look ahead." It includes logic to project the trend into the future based on current momentum:
- Forward Projection: The script calculates potential price boundaries for several bars into the future.
- Probability Bounds: By looking at the velocity and acceleration of the price, it identifies a "center" point for where the price might be heading and provides a range (bounds) of where that price is likely to settle.
Visual Output on Charts
For the user, this logic translates into several visual components on the trading chart:
- The Trend Line: The primary path calculated by the Kalman Filter.
- Volatility Bands: Multiple sets of lines (based on different deviation levels) that show the "safe zones" or high-volatility areas.
- Status Updates: The script can print real-time data to the terminal, such as current suppression levels, price speed (pips per bar), and specific predictive coordinates for future price targets.
Summary of User Experience
To a trader, this script acts as a "noise filter." It strips away the erratic "wiggles" of the forex market to show the dominant flow of the trend. It provides a more reactive way to see where the price is going compared to traditional indicators, while offering mathematical "confidence zones" to help identify when a move might be overextended.
#property copyright "Copyleft © 2007, GammaRat Forex"
#property link      "http://www.gammarat.com/Forex/"


//#include <GRFMatrixMath.mqh>
#property indicator_chart_window
#property indicator_buffers 7
#property indicator_color1 Yellow
#property indicator_color2 Yellow
#property indicator_color3 Yellow
#property indicator_color4 Red
#property indicator_color5 Red
#property indicator_color6 Red
#property indicator_color7 Red
#property indicator_style1 0
#property indicator_style2 2
#property indicator_style3 2
#property indicator_style4 2
#property indicator_style5 2
#property indicator_style6 0
#property indicator_style7 0


//---- input parameters
extern double Samples=60;
extern double DevLevel1 = 1;
extern double DevLevel2 = 2;
extern double Suppression_dB = 0;
extern double PredictBars1 = 4;
extern double PredictBars2 = 8;
extern bool PrintCurrentState = true;
extern bool AutoGainOn = true;


//---- buffers
double KalmanBuffer[];
double KalmanBufferPlus1[];
double KalmanBufferNeg1[];
double KalmanBufferPlus2[];
double KalmanBufferNeg2[];
double KalmanBufferPlus3[];
double KalmanBufferNeg3[];
double xkk[2][1],xkk1[2][1],xk1k1[2][1],yk[1][1],zk[1][1];
double Pkk[2][2],Pkk1[2][2],Pk1k1[2][2],Pkk_inv[2][2];
double Qkk[2][2],Hk[1][2],Hk_t[2][1],Sk[1][1],Sk_inv[1][1],Rk[1][1],Kk[2][1];
double Fk[2][2],Fk_t[2][2],GGT[2][2];
double Eye[2][2];
double temp22[2][2],temp21[2][1],temp12[1][2],temp11[1][1];
double xp[1][1],xpt[1][1],xpt_t[1][1];
double Phi1[1][2],Phi2[1][2];
double xdel[1][1],xdel_t[1][1];
double LookAhead=0;
static bool initiated=false;
static double c0_above=0, c0_below = 0;
static double c1_above=0, c1_below = 0;
static int last_time=-1;
static int tick_count=0;
//+------------------------------------------------------------------+
//| Custom indicator initialization function                         |
//+------------------------------------------------------------------+
int init()
  {
//---- indicators
   if(LookAhead <0)LookAhead=0;
   SetIndexStyle(0,DRAW_LINE);
   SetIndexBuffer(0,KalmanBuffer);
   SetIndexShift(0,LookAhead);
   SetIndexDrawBegin(0,LookAhead);
   SetIndexLabel(0,"Kalman Trend");
   if(MathAbs(DevLevel1) > 0) {
      SetIndexStyle(1,DRAW_LINE);
      SetIndexBuffer(1,KalmanBufferPlus1);
      SetIndexShift(1,0);
      SetIndexDrawBegin(1,1);
      SetIndexLabel(1,"Kalman +" + DoubleToStr(DevLevel1,1)  + " STD");
      SetIndexStyle(2,DRAW_LINE);
      SetIndexBuffer(2,KalmanBufferNeg1);
      SetIndexShift(2,0);
      SetIndexDrawBegin(2,1);
      SetIndexLabel(2,"Kalman -" + DoubleToStr(DevLevel1,1) + " STD");
    }
   if(MathAbs(DevLevel2) > 0){
      SetIndexStyle(3,DRAW_LINE);
      SetIndexBuffer(3,KalmanBufferPlus2);
      SetIndexShift(3,0);
      SetIndexDrawBegin(3,1);
      SetIndexLabel(3,"Kalman +" + DoubleToStr(DevLevel2,1) + " STD");
      SetIndexStyle(4,DRAW_LINE);
      SetIndexBuffer(4,KalmanBufferNeg2);
      SetIndexShift(4,0);
      SetIndexDrawBegin(4,1);
      SetIndexLabel(4,"Kalman -" + DoubleToStr(DevLevel2,1) + " STD");

      SetIndexStyle(5,DRAW_LINE);
      SetIndexBuffer(5,KalmanBufferPlus3);
      SetIndexShift(5,0);
      SetIndexDrawBegin(5,1);
      SetIndexLabel(5,"Kalman High +" + DoubleToStr(DevLevel2,1) + " STD");
      SetIndexStyle(6,DRAW_LINE);
      SetIndexBuffer(6,KalmanBufferNeg3);
      SetIndexShift(6,0);
      SetIndexDrawBegin(6,1);
      SetIndexLabel(6,"Kalman Low -" + DoubleToStr(DevLevel2,1) + " STD");
   }
//----
   return(0);
  }
//| Point and figure                                |
//+------------------------------------------------------------------+
int start()
{
   compute();
   return(0);
}
int compute(){
   int    i,j,counted_bars=IndicatorCounted();
   static bool initiated=false;
   double g,g1;
   double c0;
   static double c0_above=0, c0_below = 0;
   static double c1_above=0, c1_below = 0;
   static double acc_sigma2;
   static double z_sigma2;
   static double normalization_time;
   static double working_samples;
   double z,diff;
   double ts[3][1];
   static double dev_level1,dev_level2;
   double temp11a[1][1],temp21a[2][1];
   double temp22a[2][2];
   static double ZGain = 0;
   static double AGain=1;
   static double tgain=1;
   static double time_last;
   static double zk_saved[2][1];
   int trial;
   //----
   //give it some time to warm up
   if(Bars<Samples*2)
      return(0);
   //rewrite the last bar
   if(Time[0] <= last_time) return(0);
   tick_count--;
   if(tick_count>0)return(0);
   tick_count=2;
   last_time=Time[0];

   if(!initiated){

      Phi1[0][0] = 1;
      Phi1[0][1] = PredictBars1;
      Phi2[0][0] = 1;
      Phi2[0][1] = PredictBars2;

      dev_level1 = DevLevel1*MathSqrt(2);
      dev_level2 = DevLevel2*MathSqrt(2);
      ArrayCopy(KalmanBuffer,High);
      xkk1[0][0] = get_avg(Bars-1);
      xkk1[1][0] = 0;
      //MatrixPrint(xkk);
      MatrixEye(Pkk1);
      Fk[0][0] = 1;
      Fk[0][1]=1;
      Fk[1][0]=0;
      Fk[1][1] =1;
      MatrixTranspose(Fk,Fk_t);
      Qkk[0][0] = 1;
      Qkk[0][1] = 0;
      Qkk[1][0]=0;
      Qkk[1][1] = 1;
      GGT[0][0]=.25;
      GGT[1][0]=.5;
      GGT[0][1]=.5;
      GGT[1][1]=1;
      Hk[0][0] = 1;
      Hk[0][1] = 0;
      MatrixTranspose(Hk,Hk_t);

      Rk[0][0] = .1;
      MatrixEye(Eye);
      ZGain = 0;
      z_sigma2 = MathPow(10,-ZGain);
      acc_sigma2 = Point*MathPow(10,-Suppression_dB/20.);//*MathSqrt(0.0001/Point);
      MatrixScalarMul(acc_sigma2,Pkk1);
      working_samples = Samples;
      acc_sigma2 *= acc_sigma2;
       Rk[0][0] = z_sigma2;
      initiated = true;
      MatrixScalarMul(acc_sigma2,Pkk);
      //Print(1./MathSqrt(acc_sigma2));
      //Print(" ");
      AGain=1;
      zk_saved[0][0] = get_avg(Bars-1);
      zk_saved[1][0] = 0;

   }

   for(i=Bars-counted_bars; i> 0;i--){ //ticks are handled elsewhere

     //Start the update procedure
      MatrixZero(yk);
      zk[0][0] = get_avg(i);
      zk[1][0]= zk[0][0]-zk_saved[0][0];
      ArrayCopy(zk_saved,zk);
      diff = (zk[0][0]*Point-KalmanBuffer[i]);
      if(diff>=0) {
         diff = diff*diff;
         c0_above = (c0_above*(working_samples-1)+MathPow(get_avg(i)*Point-KalmanBuffer[i],2))/working_samples;
         c0_below = c0_below*(working_samples-1)/working_samples;
         c1_above = (c1_above*(working_samples-1)+MathPow(High[i]-KalmanBuffer[i],2))/working_samples;
         c1_below = c1_below*(working_samples-1)/working_samples;
      }else{
         diff = diff*diff;
         c0_below = (c0_below*(working_samples-1)+MathPow(get_avg(i)*Point-KalmanBuffer[i],2))/working_samples;
         c0_above = c0_above*(working_samples-1)/working_samples;
         c1_below = (c1_below*(working_samples-1)+MathPow(Low[i]-KalmanBuffer[i],2))/working_samples;
         c1_above = c1_above*(working_samples-1)/working_samples;
      }
      if(MathAbs(DevLevel1)>0){
         KalmanBufferPlus1[i-1] = KalmanBuffer[i]+dev_level1*MathSqrt(c0_above);
         KalmanBufferNeg1[i-1] = KalmanBuffer[i]-dev_level1*MathSqrt(c0_below);
      }
      if(MathAbs(DevLevel2)>0){
         KalmanBufferPlus2[i-1] = KalmanBuffer[i]+dev_level2*MathSqrt(c0_above);
         KalmanBufferNeg2[i-1] = KalmanBuffer[i]-dev_level2*MathSqrt(c0_below);
         KalmanBufferPlus3[i-1] = KalmanBuffer[i]+dev_level2*MathSqrt(c1_above);
         KalmanBufferNeg3[i-1] = KalmanBuffer[i]-dev_level2*MathSqrt(c1_below);
      }
      //this is always left alone, for now


      ArrayCopy(Qkk,GGT);

      // set the auto gain
      if(AutoGainOn && MathSqrt((c0_above+c0_below)/2)> Point){
         if(c0_below >0 || c0_above>0)
            tgain = MathAbs((c0_below)/(c0_below+c0_above));
         else tgain = 0.5;
         if(tgain< 0.2 || tgain > 0.8)
            AGain = AGain*MathPow(10,0.005);
         else if(tgain> 0.4 && tgain < 0.6)
            AGain=AGain*MathPow(10,-0.005);
      }else{
         AGain = 1;
      }
      tgain = AGain*acc_sigma2;
      MatrixScalarMul(tgain,Qkk);
      MatrixMul(Hk,xkk1,temp11);
      //MatrixPrint(xkk1);
      MatrixAdd(zk,temp11,yk, -1);
      MatrixMul(Hk,Pkk1,temp12);
      MatrixMul(temp12,Hk_t,temp11);
      MatrixAdd(temp11,Rk,Sk,1);
      MatrixInvert(Sk,Sk_inv);
      MatrixMul(Pkk1,Hk_t,temp21);
      MatrixMul(temp21,Sk_inv,Kk);
      MatrixMul(Kk,yk,temp21);
      MatrixAdd(temp21,xkk1,xkk,1);

      MatrixMul(Kk,Hk,temp22);
      MatrixAdd(Eye,temp22,temp22a,-1);
      MatrixMul(temp22a,Pkk1,Pkk);

      //predict cycle
          //make copies of the last iteration;
      ArrayCopy(Pk1k1,Pkk);
      ArrayCopy(xk1k1,xkk);
      //g = MathSqrt(MathPow(xkk[0][0]-get_avg(i),2))/Pkk[0][0]*Point;
      //g = xkk[1][0];
      //predict the state
      //Print("Doing Predict");
      MatrixMul(Fk,xk1k1,xkk1);
      //MatrixPrint(xkk1);
      MatrixMul(Fk,Pk1k1,temp22);
      MatrixMul(temp22,Fk_t,Pk1k1);
      MatrixAdd(Pk1k1,Qkk,Pkk1,1);
      //Print("Predict Ended");
      KalmanBuffer[i-1] = (xkk1[0][0]*Point);

      if(i==1){
         if(PrintCurrentState){
            Print("Suppression (dB):", -20*MathLog(MathSqrt(tgain)/Point)/MathLog(10.),"dB; Value:",xkk1[0][0]*Point
            ,"; Speed (pips/bar):",xkk1[1][0],"; dp/p:"
            , xkk1[1][0]/xkk1[0][0]*100.*240.*(24.*60.)/Period());
         }
         if(PredictBars1 > 0){
            MatrixMul(Phi1,xkk,xpt);
            xp[0][0] = xkk[0][0];

            MatrixTranspose(Phi1,temp21);
            MatrixMul(Pkk,temp21,temp21a);
            MatrixMul(Phi1,temp21a,temp11a);
            MatrixInvert(temp11a,temp11);
            MatrixAdd(xp,xpt,xdel,-1);
            MatrixTranspose(xdel,xdel_t);
            MatrixMul(temp11,xdel,temp11a);
            MatrixMul(xdel_t,temp11a,temp11);
            g1=MathSqrt(temp11[0][0]);
            Print(Phi1[0][1], " bar bounds ",(xpt[0][0]-g1)*Point
               ,",",(xpt[0][0]+g1)*Point);
            Print(Phi1[0][1], " bar center, r(t) (in pips) ",(xpt[0][0])*Point
               ,",",g1);
         }
         if(PredictBars2 > 0){
            MatrixMul(Phi2,xkk,xpt);
            xp[0][0] = xkk[0][0];
            MatrixTranspose(Phi2,temp21);
            MatrixMul(Pkk,temp21,temp21a);
            MatrixMul(Phi2,temp21a,temp11a);
            MatrixInvert(temp11a,temp11);
            MatrixAdd(xp,xpt,xdel,-1);
            MatrixTranspose(xdel,xdel_t);
            MatrixMul(temp11,xdel,temp11a);
            MatrixMul(xdel_t,temp11a,temp11);
            g1=MathSqrt(temp11[0][0]);
            Print(Phi2[0][1], " bar bounds ",(xpt[0][0]-g1)*Point
               ,",",(xpt[0][0]+g1)*Point);
            Print(Phi2[0][1], " bar center, r(t) (in pips) ",(xpt[0][0])*Point
               ,",",g1);
         }
      }else g= -1;


   }
   //Print("24 hours:", xpt[0][0]*Point," ,Gate ",g);
   //Print ("Gate 2 ", MathSqrt(xdel[0][0]*xdel[0][0]*g)*Point," g1 ",g1);

}

 double get_avg(int k){
   return(MathPow((High[k]*Low[k]*Close[k]*Close[k]),1/4.)/Point);
}
//+++++++-----------------------------------------------------+
double determinant_fixed(double a[][], int k){
   double z;
    switch(k){
      case 1: return(a[0][0]);
         break;
      case 2: return( a[0][0]*a[1][1]-a[1][0]*a[0][1]);
         break;
      case 3:
         z = a[0][0]*a[1][1]*a[2][2] + a[0][1]*a[1][2]*a[2][0] +
             a[0][2]*a[1][0]*a[2][1] -
            (a[2][0]*a[1][1]*a[0][2] + a[1][0]*a[0][1]*a[2][2] +
             a[0][0]*a[2][1]*a[1][2]);
         return(z);
         break;
      default:
          Print("array_range too large for determinant calculation");
         return(0);
   }
}
double determinant(double a[][]){
   double z;
   if(ArrayRange(a,0) != ArrayRange(a,1)){
      Print("Non-square array entered into determinant");
      return(0);
    }
    switch(ArrayRange(a,0)){
      case 1: return(a[0][0]);
         break;
      case 2: return( a[0][0]*a[1][1]-a[1][0]*a[0][1]);
         break;
      case 3:
         z = a[0][0]*a[1][1]*a[2][2] + a[0][1]*a[1][2]*a[2][0] +
             a[0][2]*a[1][0]*a[2][1] -
            (a[2][0]*a[1][1]*a[0][2] + a[1][0]*a[0][1]*a[2][2] +
             a[0][0]*a[2][1]*a[1][2]);
         return(z);
         break;
      default:
          Print("array_range too large for determinant calculation");
         return(0);
   }
}

int MatrixAdd(double a[][], double b[][],double & c[][],double w=1){
   int i,j;
   for(i=0;i<ArrayRange(c,0);i++){
      for(j=0;j<ArrayRange(c,1);j++){
         c[i][j] = a[i][j]+w*b[i][j];
      }
   }
    return(0);
}
int MatrixMul(double a[][], double b[][],double & c[][]){
   int i,j, k;
   if(ArrayRange(a,1) != ArrayRange(b,0)){
      Print("array Range Mismatch in Matrix Mul");
      return(-1);
   }
   for(i=0;i<ArrayRange(a,0);i++){
      for(j=0;j<ArrayRange(b,1);j++){
         c[i][j] = 0;
         for(k=0;k<ArrayRange(a,1);k++){
           c[i][j] += (a[i][k]*b[k][j]);
         }
      }
   }
  return(0);
}
int MatrixScalarMul(double b,double & a[][]){
   int i,j;
   for(i =0;i<ArrayRange(a,0);i++){
      for(j=0;j<ArrayRange(a,1);j++){
         a[i][j] *= b;
      }
   }
}
int MatrixInvert(double a[][],double & b[][]){
   double d;
   double temp1[4][4],temp2[4][4];
   int i,j,i1,j1,k;

   if(ArrayRange(a,0) != ArrayRange(a,1)){
      Print("Matrix Inverse attempted on non square matrix. Not implemented yet");
      return(-1);
   }
   if(ArrayRange(a,1) > 3){
      Print("Bugger off, not implemented yet");
      return(-1);
   }
   d = determinant(a);
   if(MathAbs(d)<0.000001){
    Print("unstable matrix");
    d = 1;
   }
   k = ArrayRange(a,0);
   if(k==0){
      b[0][0]=1./a[0][0];
      return(0);
   }
   d = determinant(a);
   for(i1=0;i1<k;i1++){
      for(j1=0;j1<k;j1++){
         temp1[i1][j1] = a[i1][j1];
      }
   }
   for(i=0;i<k;i++){
      for(j=0;j<k;j++){
         //copy the arry. There must be a better way!!
         ArrayCopy(temp2,temp1);
         for(j1=0;j1<k;j1++){
            if(j1==j){
               temp2[i][j1] = 1;
            }else{
               temp2[i][j1] = 0;
            }
         }
         b[i][j]=determinant_fixed(temp2,k)/d;
      }
   }
}
int MatrixTranspose(double a[][],double & b[][]){
   int i,j;
   for(i=0;i<ArrayRange(a,0);i++){
      for(j=0;j<ArrayRange(a,1);j++){
         b[j][i] = a[i][j];
      }
   }
   return(0);
 }
int MatrixZero(double & a[][]){
   int i,j;
   for(i= 0;i<ArrayRange(a,0);i++){
      for(j=0;j<ArrayRange(a,1);j++){
         a[i][j]=0;
      }
   }
   return(0);
}
int MatrixEye(double & a[][]){
   int i,j;
   for(i= 0;i<ArrayRange(a,0);i++){
      for(j=0;j<ArrayRange(a,1);j++){
         a[i][j]=0;
         if(i==j)a[i][j]=1;
      }
   }
   return(0);
}
int MatrixPrint(double a[][]){
   int i,j;
   for(i= 0;i<ArrayRange(a,0);i++){
      for(j=0;j<ArrayRange(a,1);j++){
      Print(i," ,",j," ,",a[i][j]);
      }
   }
   return(0);
}
//+------------------------------------------------------------------+
Comments